Robotics Engineer · Genova, Italy

Mohamed Eyad

I build robots that work on real hardware, in industry and healthcare.

MSc Robotics Engineering at the University of Genova, with my thesis at ETH Zurich: a real-time ROS 2 system that fuses wearable sensors with an on-device language model to support rehabilitation.

  • Genova, Italy · open to relocation
  • Available immediately · MSc defense Dec 2026
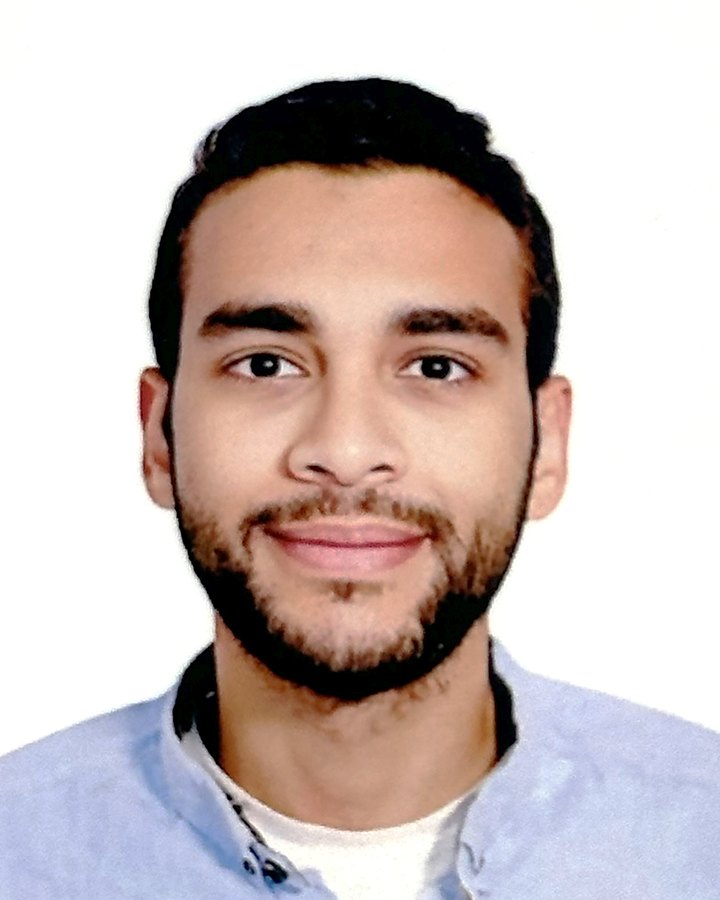
Portrait of Mohamed Eyad
Thesis at ETH ZurichSCAI Lab & DART Lab

Real-time ROS 2 systems

Synchronized wearable sensing (eye tracking, ECG) with a local LLM on an NVIDIA Jetson AGX Orin, validated in a 12-participant study.

Control on real hardware

PID speed control on a mobile robot; position, current, force, admittance and impedance control on a DC-motor test rig.

Autonomy and manipulation

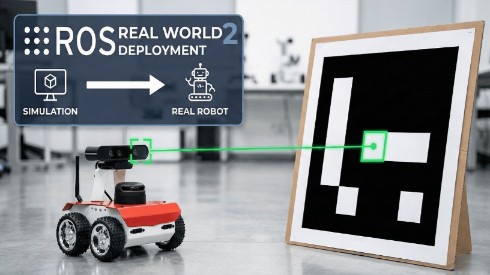
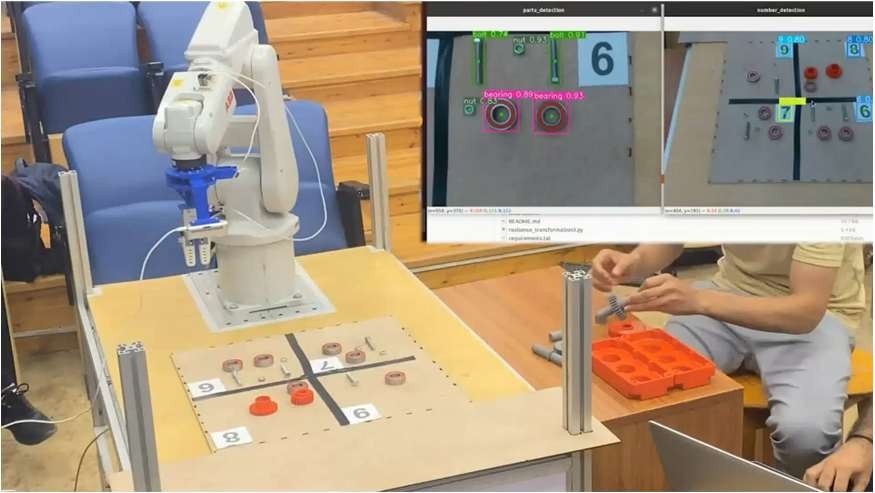
SLAM and Nav2 navigation, PDDL task planning with PlanSys2, MoveIt on an ABB arm, and visual servoing taken from simulation to a real robot.

Clinical work and teaching

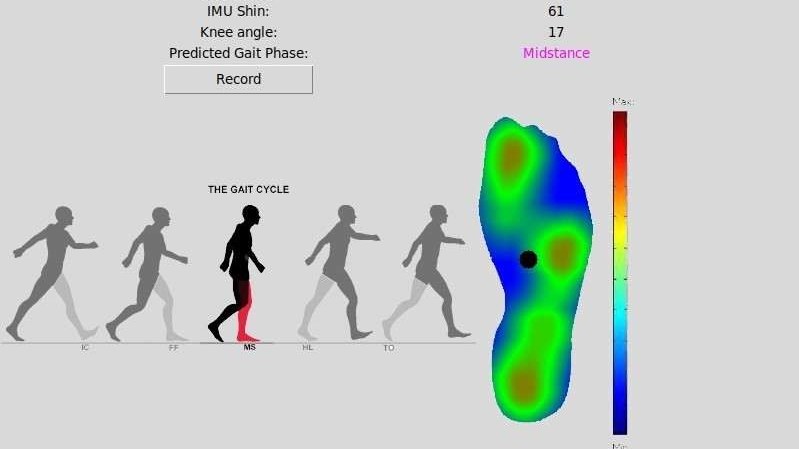
Exoskeleton sessions with spinal-cord-injury patients, gait studies with motion capture, and ROS training for 30+ students.

Who I am

About me

I'm a robotics engineer who enjoys making robots work on real hardware, alongside the people who use them. After a BSc in Mechatronics Engineering at Ain Shams University in Cairo, where I graduated 6th in my class, I moved to Italy for an MSc in Robotics Engineering at the University of Genova and carried out my thesis at ETH Zurich, building a real-time ROS 2 system that fuses wearable sensor data with a locally-run language model to support rehabilitation.

Working in research labs, a rehabilitation lab with patients, and classrooms has taught me to combine careful engineering with clear communication: from tuning controllers on a motor test rig to running sessions with participants and teaching robotics to students.

My ambition is to grow into a senior robotics and control engineer on industrial and medical systems that go into real use, while continuing to build my own projects.

Outside work I'm building a robotics learning platform with remote access to real robots and simulation. I also teach robotics and STEM, and I like running, hiking and flying drones.
Where I've worked

Experience

Research, clinical lab work and teaching, most recent first.

  1. MSc Thesis Researcher

    Mar – Aug 2026

    SCAI Lab, ETH Zurich & DART Lab, Lake Lucerne Institute · Switzerland

    • Built a real-time ROS 2 pipeline fusing HRV (Polar H10) and pupil data (Pupil Labs Neon) into a live cognitive-load index, with spoken feedback from a local LLM on an NVIDIA Jetson AGX Orin.
    • Ran a 12-participant treadmill study: the index tracked the mental task in all 12 participants and agreed with NASA-TLX ratings (r = 0.80).
    • Developed the Pupil Labs Neon driver and eye-tracking message types for the open-source ROS4Healthcare framework.
    Read about the thesis
  2. Research & Lab Engineer

    Jan – Jul 2024

    Human-Centered Mechatronics Lab, Ain Shams University · Cairo

    • Ran biomechanical and gait studies with Qualisys motion capture, AMTI force plates and Delsys Trigno EMG.
    • Operated the Fourier ExoMotus X2 exoskeleton with spinal-cord-injury patients, controlling its walking behavior through ROS (admittance control) and troubleshooting faults.
    • Tested EEG systems, 3D-scanned and printed medical components (EinScan HX, Raise3D E2), and supported student project teams.
    See the lab work
  3. Teaching Assistant

    Sep 2023 – Aug 2024

    Faculty of Engineering, Ain Shams University · Cairo

    • Delivered lab sessions for Design of Mechatronic Systems and Control System Design (MATLAB/Simulink, SolidWorks, CoppeliaSim, ROS, Arduino) and supervised robotics graduation projects.
    • Trained 30+ students in a summer ROS course: TurtleBot navigation in Gazebo/RViz, OpenCV on Raspberry Pi and rosserial.
  4. Teaching Assistant

    Sep 2023 – Jan 2024

    UPEI Cairo Campus (University of Prince Edward Island) · Cairo

    • Prepared and presented tutorials and lab sessions for Control System Design and Project-Based Professional Practice I.
  5. STEAM Facilitator & Robotics Instructor

    Mar – Oct 2023

    Edu-Zone STEAM Learning Centre · Cairo

    • Developed robotics and STEAM content and taught children aged 4 to 14 in hands-on project sessions.

What I've built

Selected projects

Open any project for the full write-up, architecture diagrams and videos.

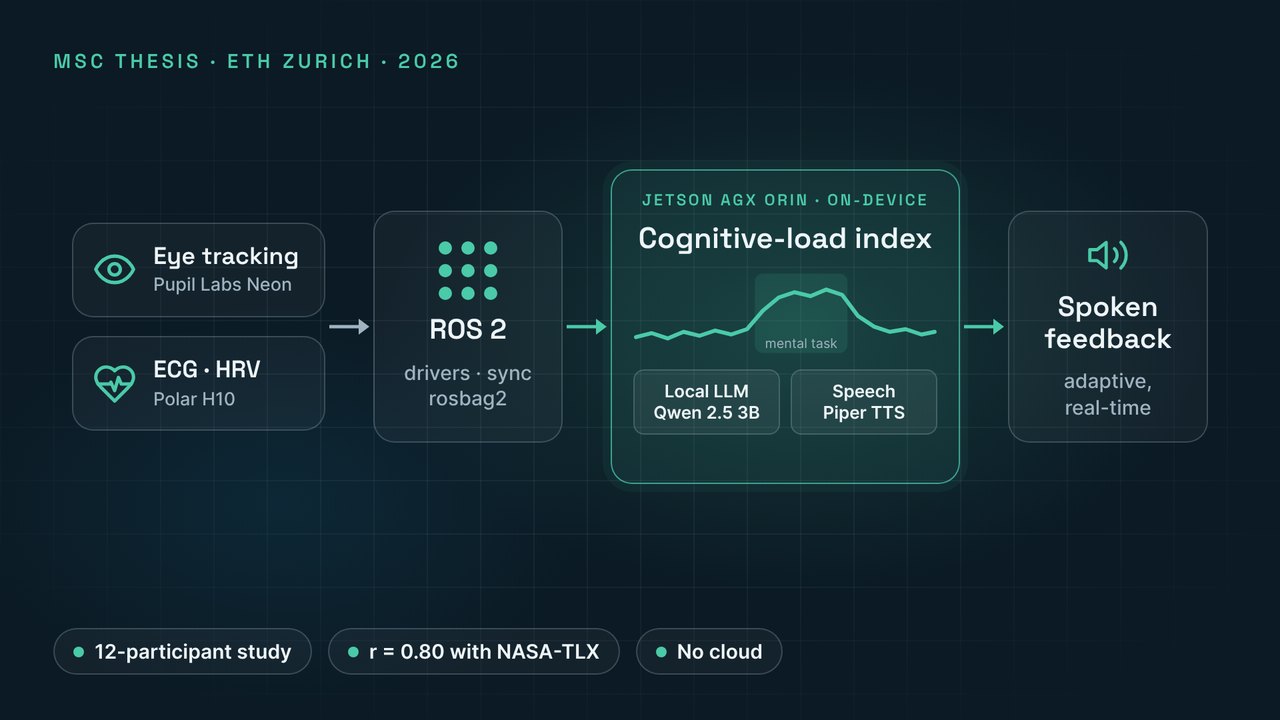
Diagram: eye tracking and ECG feed ROS 2, a cognitive-load index and local LLM run on a Jetson AGX Orin, which gives spoken feedback

2026 · MSc thesis · ETH Zurich Latest

Real-time cognitive-load estimation with wearable sensors and an on-device LLM

A ROS 2 pipeline that fuses pupil data (Pupil Labs Neon) and heart-rate variability (Polar H10) into a live cognitive-load index, with spoken feedback from Qwen 2.5 3B running locally on an NVIDIA Jetson AGX Orin.

  • 12/12participants: index tracked the task
  • r = 0.80agreement with NASA-TLX
  • On-deviceLLM and speech, no cloud
  • ROS 2
  • Python
  • Jetson AGX Orin
  • Ollama
  • Biosignals
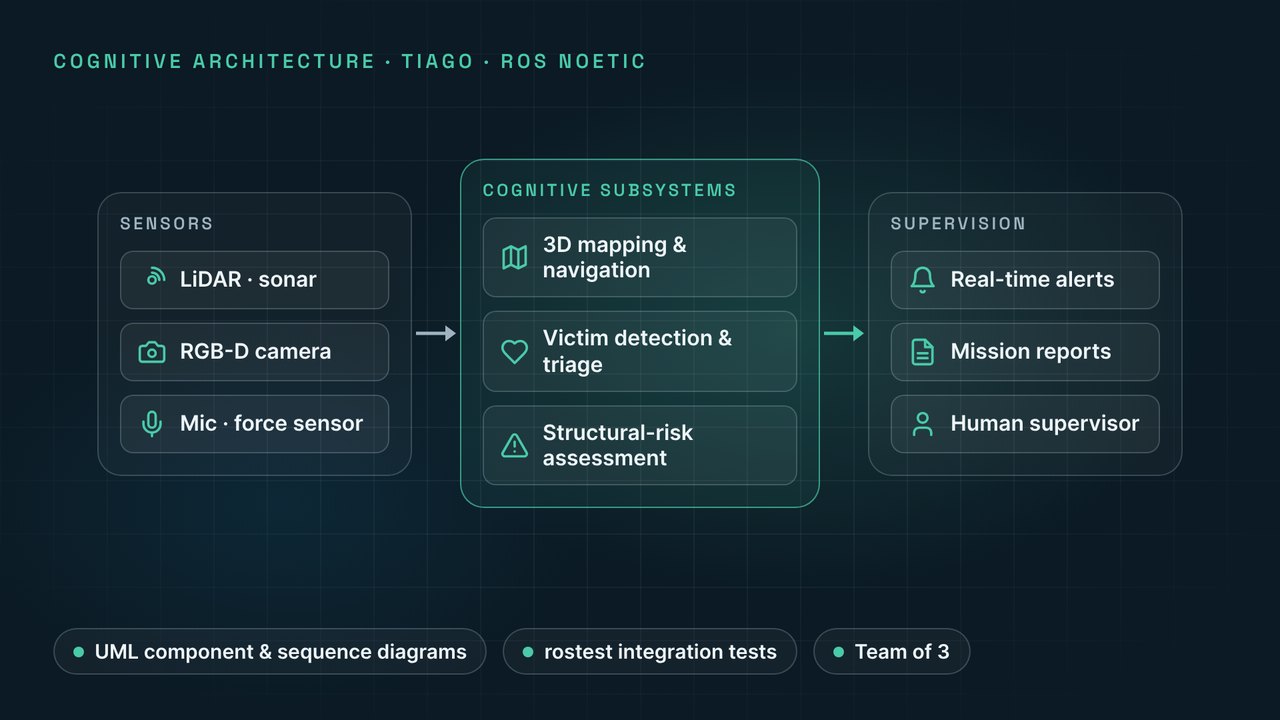
Diagram: TIAGo sensors feed navigation, victim triage and structural-risk subsystems that report to a supervisor

2025 · Team of 3 · University of Genova

Cognitive architecture for a search-and-rescue TIAGo

A modular architecture for mapping, victim triage, structural-risk assessment and reporting, prototyped in ROS Noetic with UML design and rostest integration tests.

  • ROS Noetic
  • Software architecture
  • UML
  • rostest
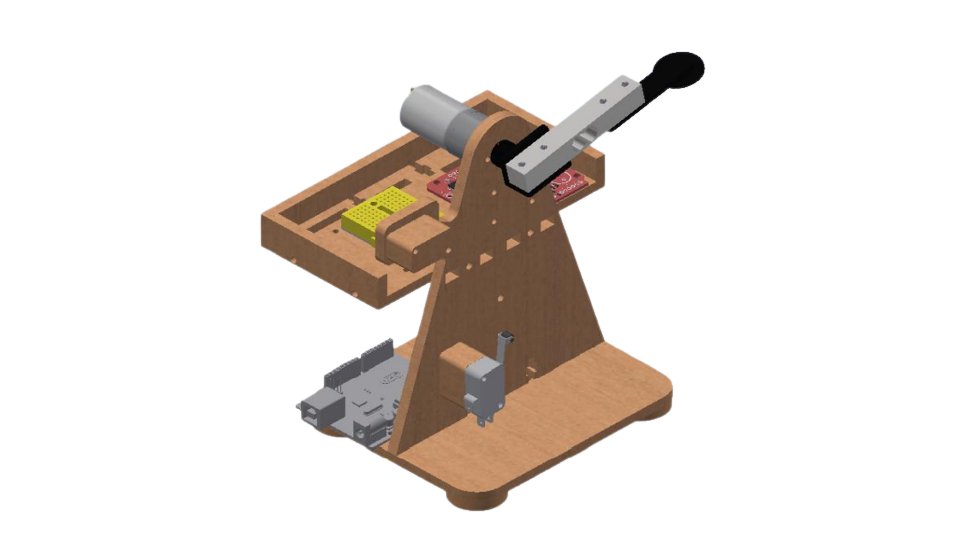
CAD model of the single-joint DC-motor test rig

2023 · Course project · Grade A

Control test rig for rehabilitation robotics

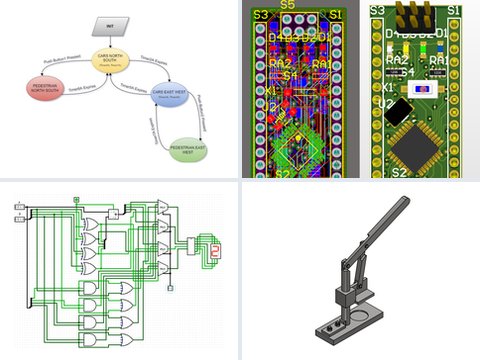
Single-joint DC-motor rig used to implement and compare position, current, force, admittance and impedance control on real hardware.

  • Control
  • MATLAB/Simulink
  • Arduino
  • Sensors
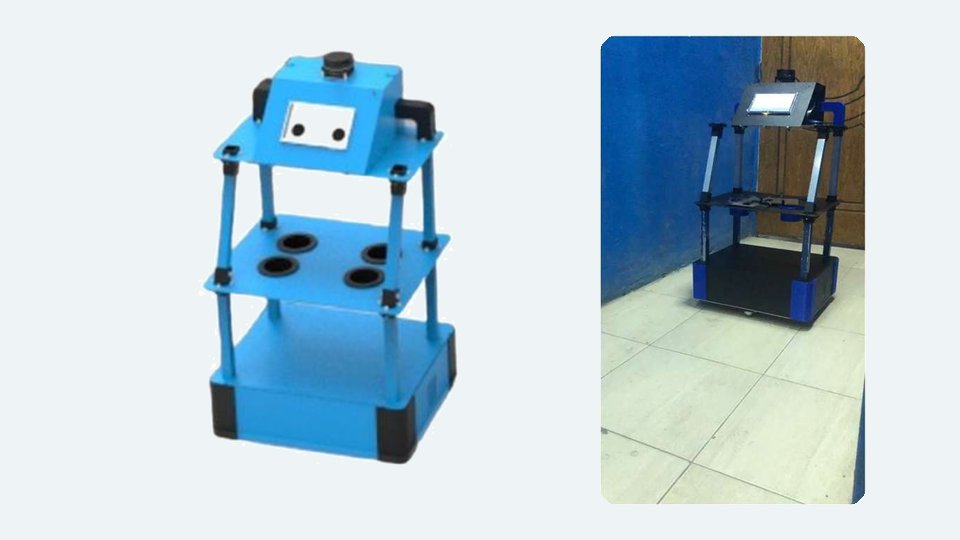
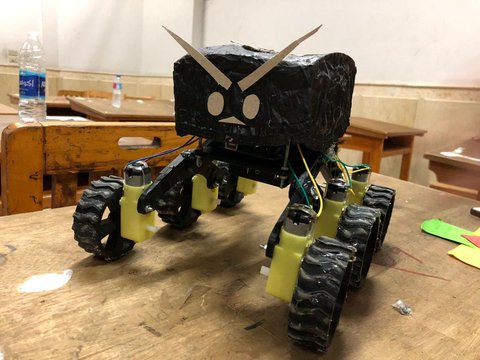
Robusta service robot: CAD render next to a photo of the built robot

2022 · Team project · Grade A

Robusta: autonomous service robot

Coffee-shop service robot with Gmapping SLAM and ROS navigation on a Jetson Nano, PID wheel control on an STM32, and customer emotion recognition.

  • ROS
  • SLAM
  • Jetson Nano
  • STM32
  • PID

More projects

Coursework and competitions from my BSc and exchange semester.

What I use

Skills

Grouped by area. The levels are the same ones I use in my CV.

  • Levels:
  • Advanced
  • Proficient
  • Basic

Robotics software

  • ROS / ROS 2
  • MoveIt
  • SLAM & navigation (Gmapping, Nav2)
  • PlanSys2 / PDDL
  • Gazebo, RViz
  • CoppeliaSim
  • ABB EGM / RWS
  • Docker

Programming

  • Python (NumPy, Pandas, PyTorch)
  • C / C++
  • MATLAB / Simulink
  • Linux, Git
  • Software architecture & UML
  • rostest, rosbag replay
  • LabVIEW

Control & signal processing

  • PID and feedback control
  • Force, admittance, impedance control
  • Sensor fusion & synchronization
  • Biosignals: ECG/HRV, PPG, EMG, EEG
  • Computer vision: OpenCV, YOLO
  • Local LLMs on edge devices (Ollama)

Hardware & tools

  • STM32, ESP32, AVR / Arduino
  • NVIDIA Jetson, Raspberry Pi
  • Qualisys, AMTI, Delsys EMG
  • CAD: Inventor, SolidWorks
  • 3D printing & scanning
  • Proteus, Altium Designer
  • PLC (Schneider Electric)
  • RTOS

Communication

  • UART, I2C, SPI
  • Bluetooth Low Energy, Wi-Fi
  • ROS topics & services, rosserial

Languages

  • English C1 · professional
  • Italian A2 · elementary
  • Arabic Native

Where I studied

Education

2024 – 2026

MSc Robotics Engineering

University of Genova, Italy

Thesis at ETH Zurich (SCAI Lab) and the DART Lab, Lake Lucerne Institute: real-time ROS 2 multimodal sensing with LLM feedback for rehabilitation. Defense in December 2026.

2018 – 2023

BSc Mechatronics Engineering & Automation

Ain Shams University, Cairo, Egypt

GPA 3.53/4, ranked 6th in class. Graduation project (human-robot collaborative assembly) graded A+.

2020

Erasmus+ exchange semester

University of Lancashire (formerly UCLan), UK

Mechatronics and Intelligent Machines. Fully funded; grade: Distinction.

Courses and certificates

  • 2023IoT Fundamentals: Connecting ThingsCisco Networking Academy
  • 2023Internet of Things and Artificial IntelligenceNational Telecommunication Institute (NTI)
  • 2022Robotics software trainingASmarine Academy · Python, Git, ROS, Gazebo; TurtleBot3 navigation project
  • 2021 – 22Embedded Systems DiplomaEmbedded C, AVR drivers and interfacing
  • 2020PLC & Industrial Automation summer trainingSchneider Electric Egypt
  • 2020Introduction to Biomedical EngineeringCoursera

Contact

Let's talk

I'm open to robotics and control engineering roles, in Italy or abroad, and happy to talk about any of these projects. Email is the fastest way to reach me: mooeyad@gmail.com