Industrial Robotics course

6-DOF manipulator control in ROS

Modeling a 6-DOF manipulator, planning a trajectory to a Cartesian goal with MoveIt, and tracking it in Gazebo with a PID controller on each joint.

  • CourseIndustrial Robotics, Ain Shams University
  • StackROS · URDF · MoveIt · Gazebo
  • ControlPID on each joint

Milestones

  1. Model a 6-DOF manipulator with our own dimensions in a URDF file and test it in RViz.
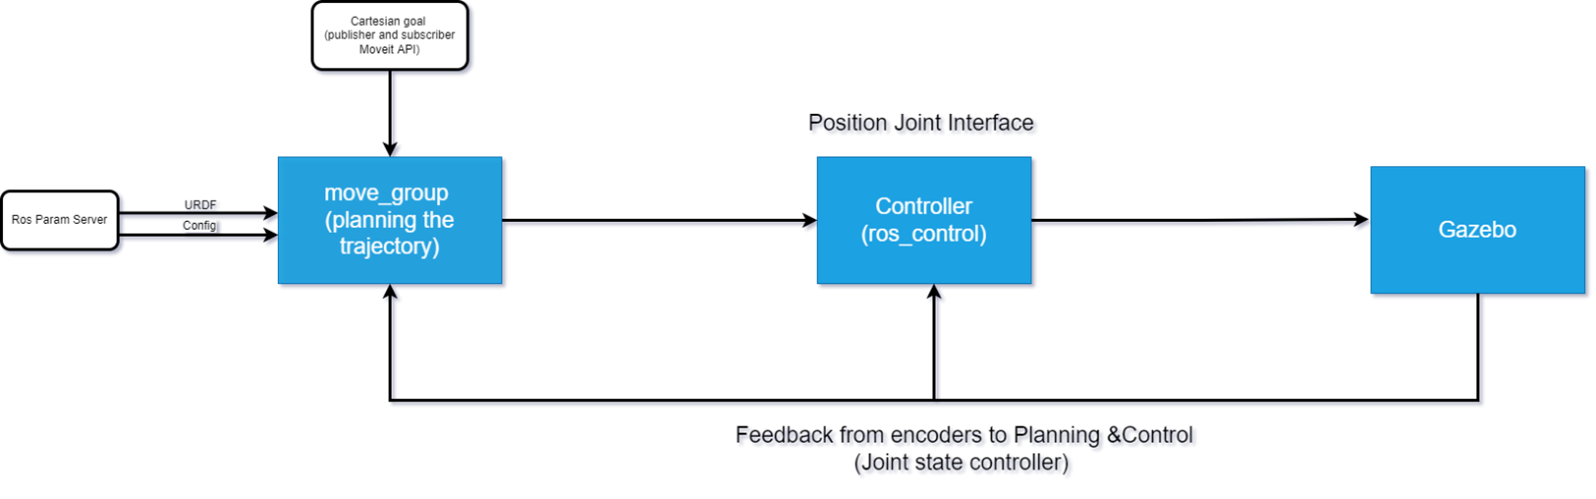
  2. Use MoveIt to plan a trajectory to a given Cartesian goal and visualize the motion of the robot in RViz.
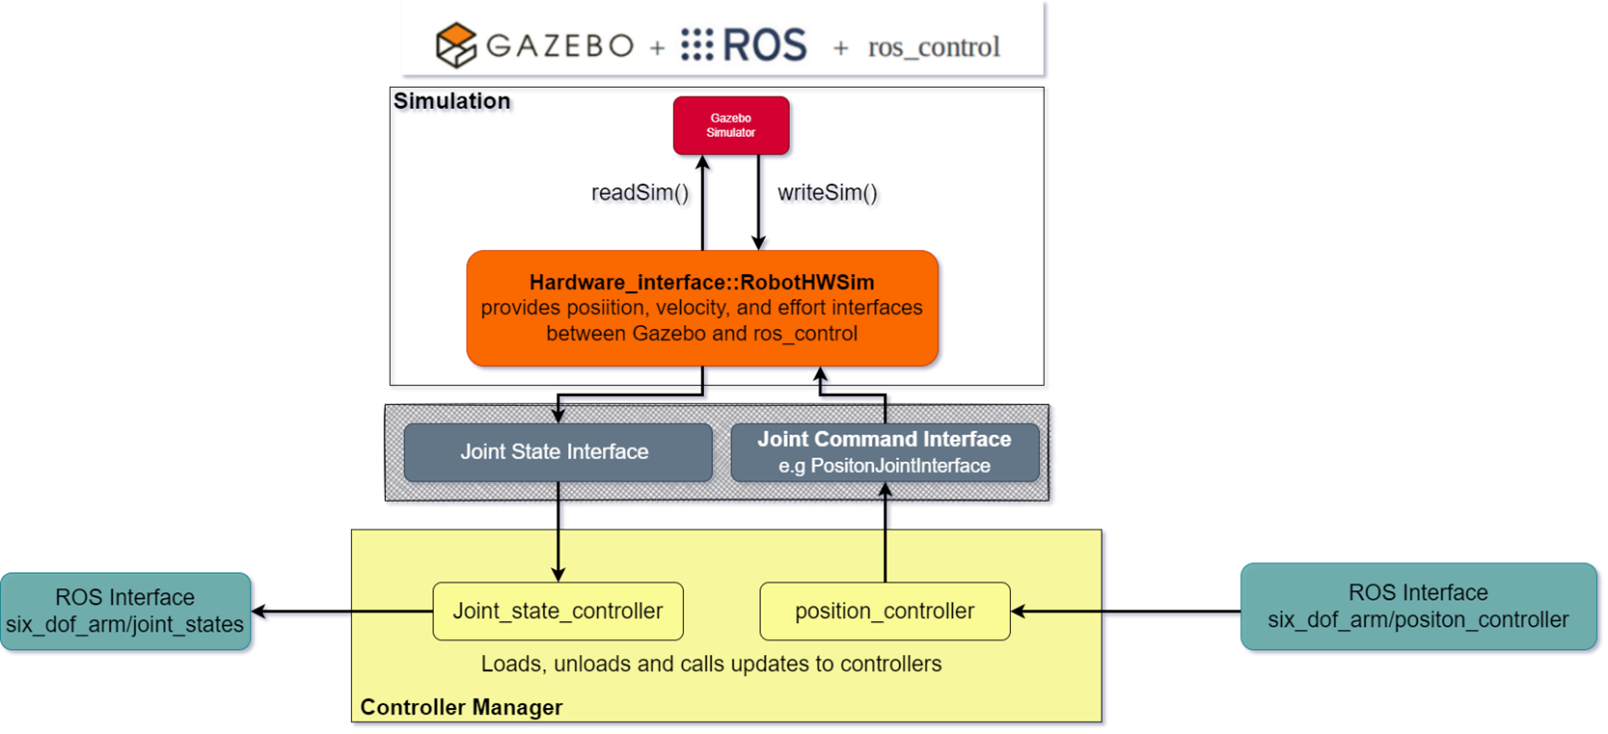
  3. Use the joint angles from MoveIt as setpoints for a PID controller on each joint in Gazebo, and reach the desired goal.
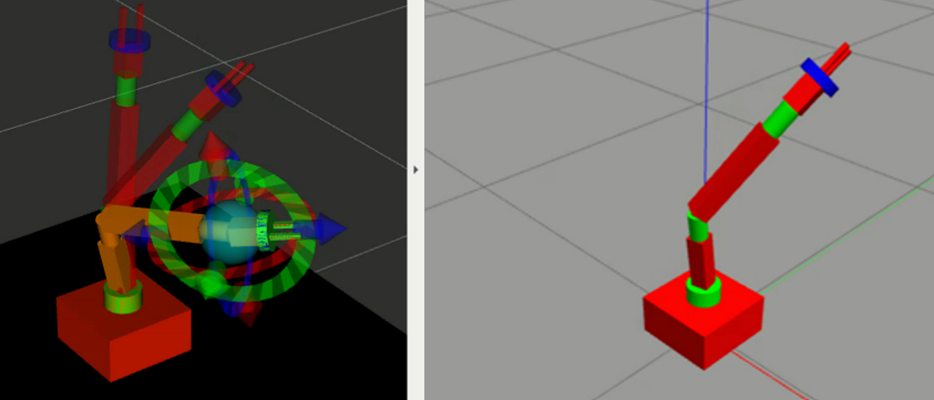
The modelled arm in RViz with a planned trajectory, and the same arm in Gazebo
The arm in RViz with its planned trajectory, and in Gazebo.

Video

Project walkthrough, narrated by me · Open in Google Drive

Tech stack

  • ROS
  • URDF
  • MoveIt
  • RViz
  • Gazebo
  • ros_control
  • PID
  • Python