Design of Mechatronics 2 course · 2022 · Grade A

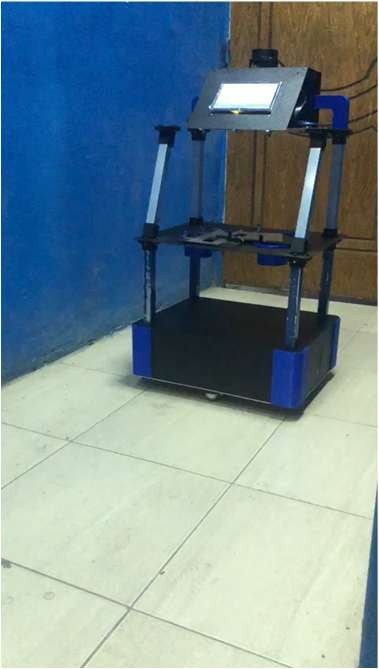
Robusta: autonomous service robot

A team project to design and build an autonomous mobile robot that serves customers in coffee shops.

  • CourseDesign of Mechatronics 2, Ain Shams University
  • ComputeNVIDIA Jetson Nano · STM32 low-level controller
  • SoftwareROS · Gmapping · Navigation Stack
  • ToolsInventor · SolidWorks · Gazebo · RViz · Arduino IDE

Requirements

  • Navigate autonomously indoors: localize within the working environment, and detect and avoid static and dynamic obstacles.
  • Build a map of a new environment on the first run, then localize in it. An RPLidar interfaced with an NVIDIA Jetson Nano runs the ROS Gmapping package, which is based on the FastSLAM algorithm.
  • Control the speed of the robot with PID controllers and wheel encoders on the low-level controller (STM32).
  • Recognize the customer's emotions with computer vision.

System design
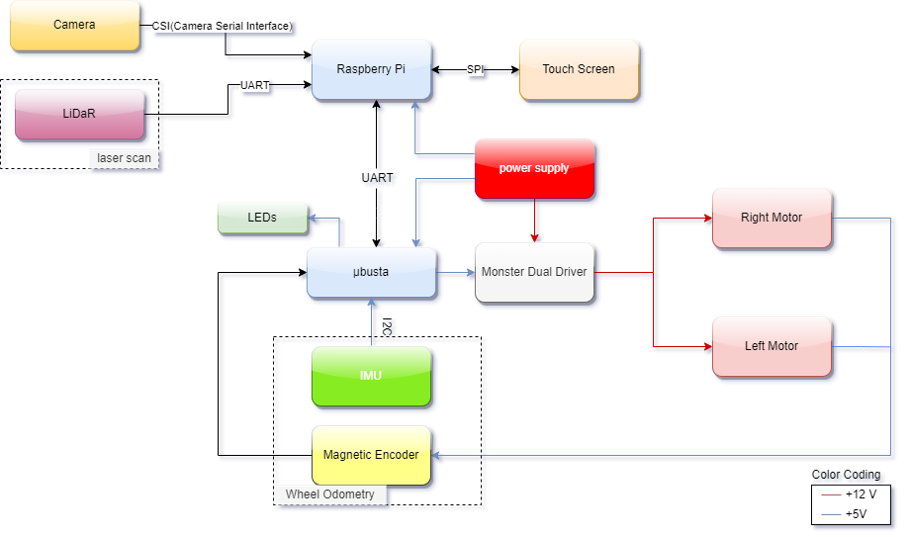
Block diagram of Robusta: sensors, actuators and the communication links between the devices
System block diagram: sensors, actuators and the communication between devices.
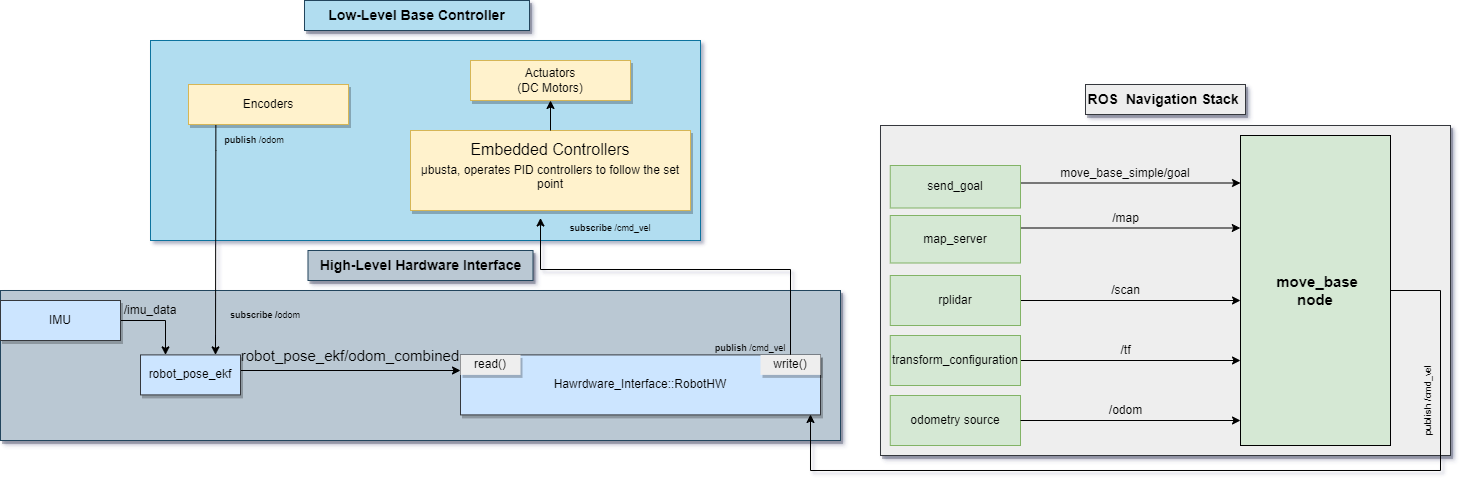
Software architecture diagram of Robusta
Software architecture.

Testing the subsystems

Testing mapping with the RPLidar in RViz.
Interfacing the RPLidar with the Jetson Nano.
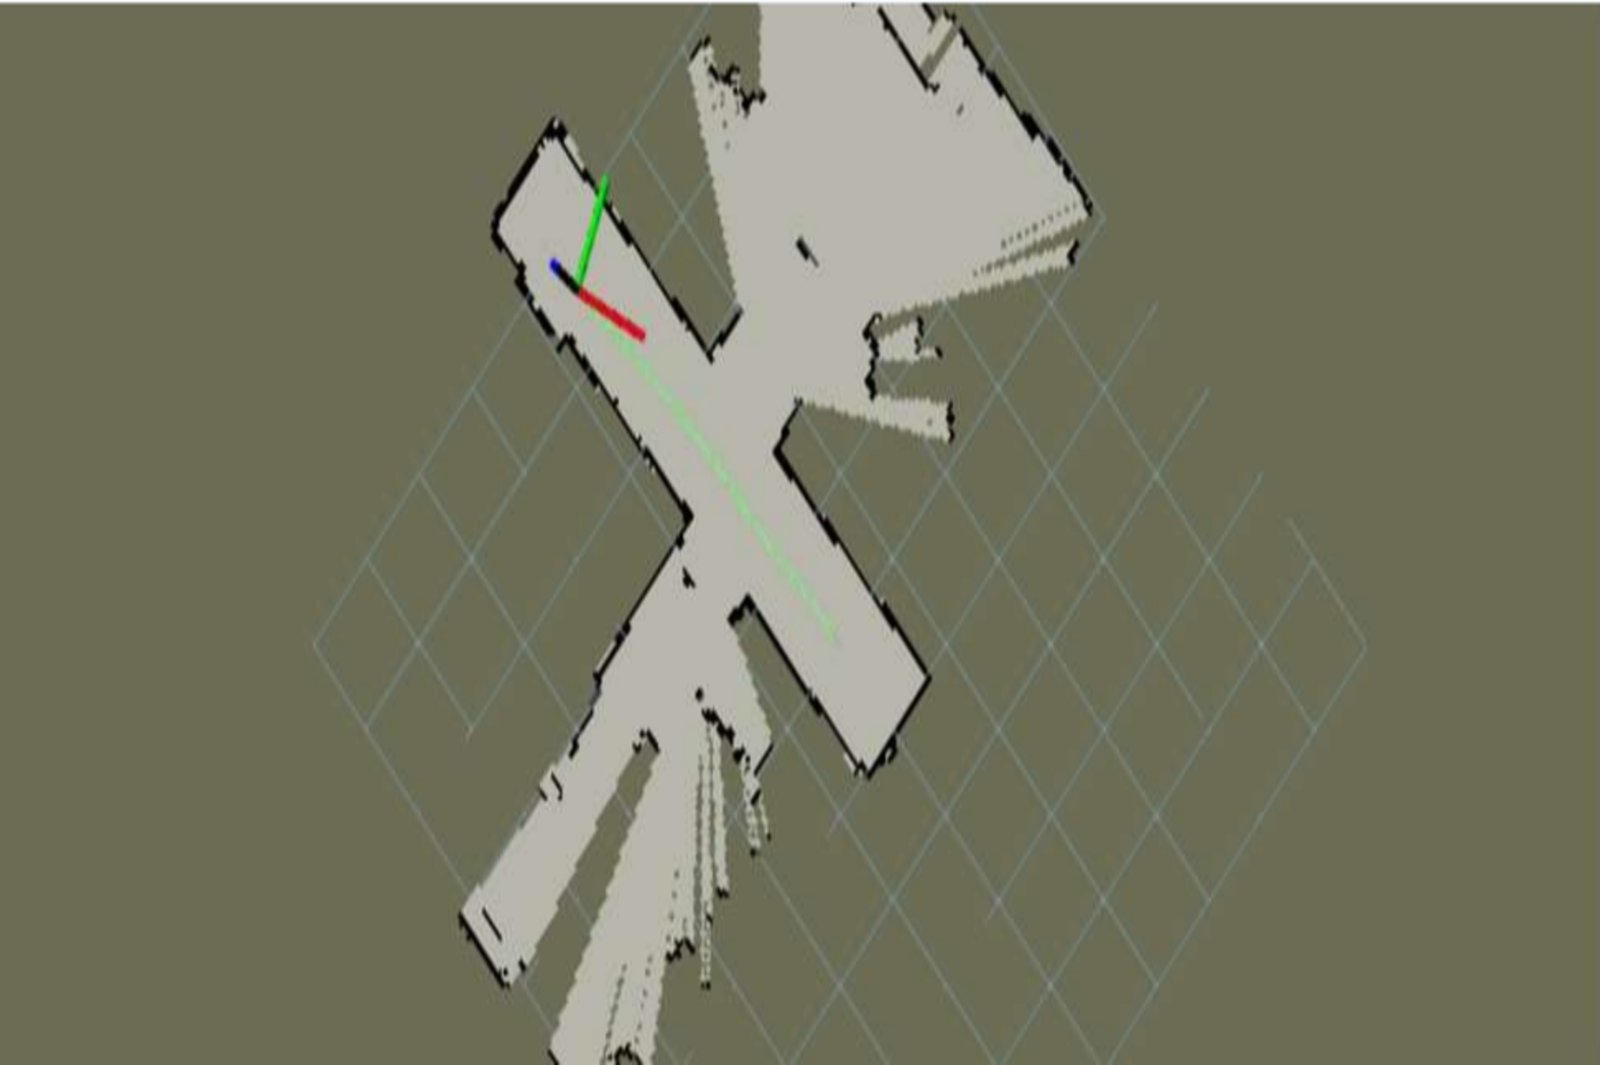
Occupancy-grid map of an indoor space built by the robot
A map built by the robot in the real environment.
Mapping the real environment.

Simulation

Mapping the environment for the first time with Gmapping SLAM in Gazebo.
Navigation and the whole service cycle.

After the course, the team planned to develop Robusta further for a coffee shop in Egypt.

Tech stack

  • ROS
  • Gmapping
  • Navigation Stack
  • NVIDIA Jetson Nano
  • RPLidar
  • STM32
  • PID
  • Gazebo
  • RViz
  • Inventor
  • SolidWorks